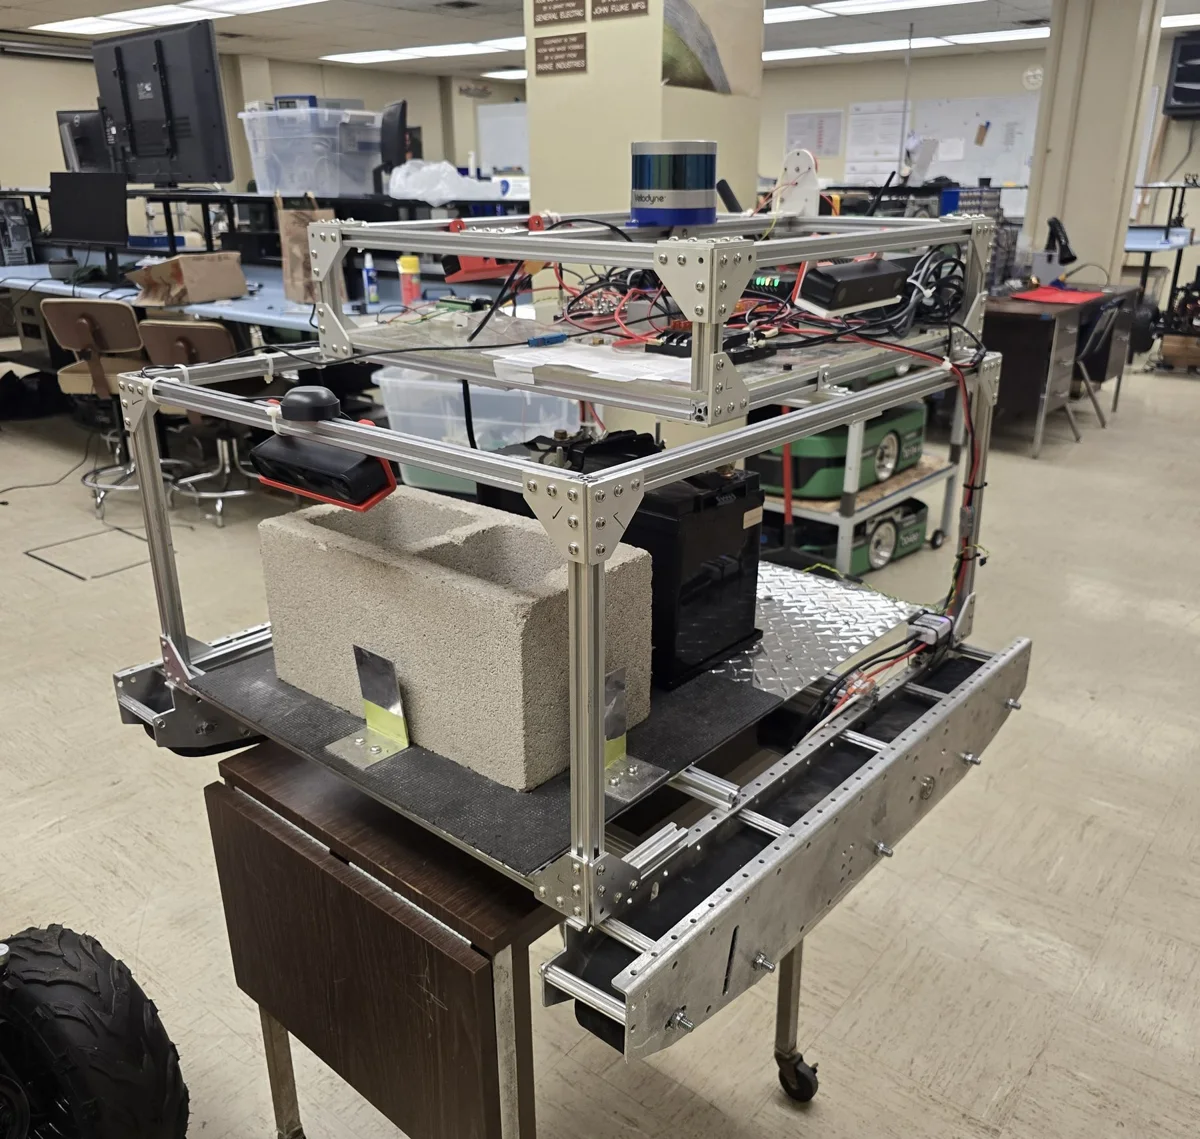
Helping the team compare its MARVIN rover simulation with physical tests.
My work
I'm helping the Autonomous Vehicle Lab develop and check the Gazebo digital twin of its MARVIN tracked rover. My current work supports the comparison between recorded physical tests and the simulation.
Also at Cal Poly Pomona
Separately, I review research on AI for digital twins with Professor Tamer Omar, focusing on how the models are implemented and evaluated.