Working through the geometry of a disc-and-thread soft robot.
My work
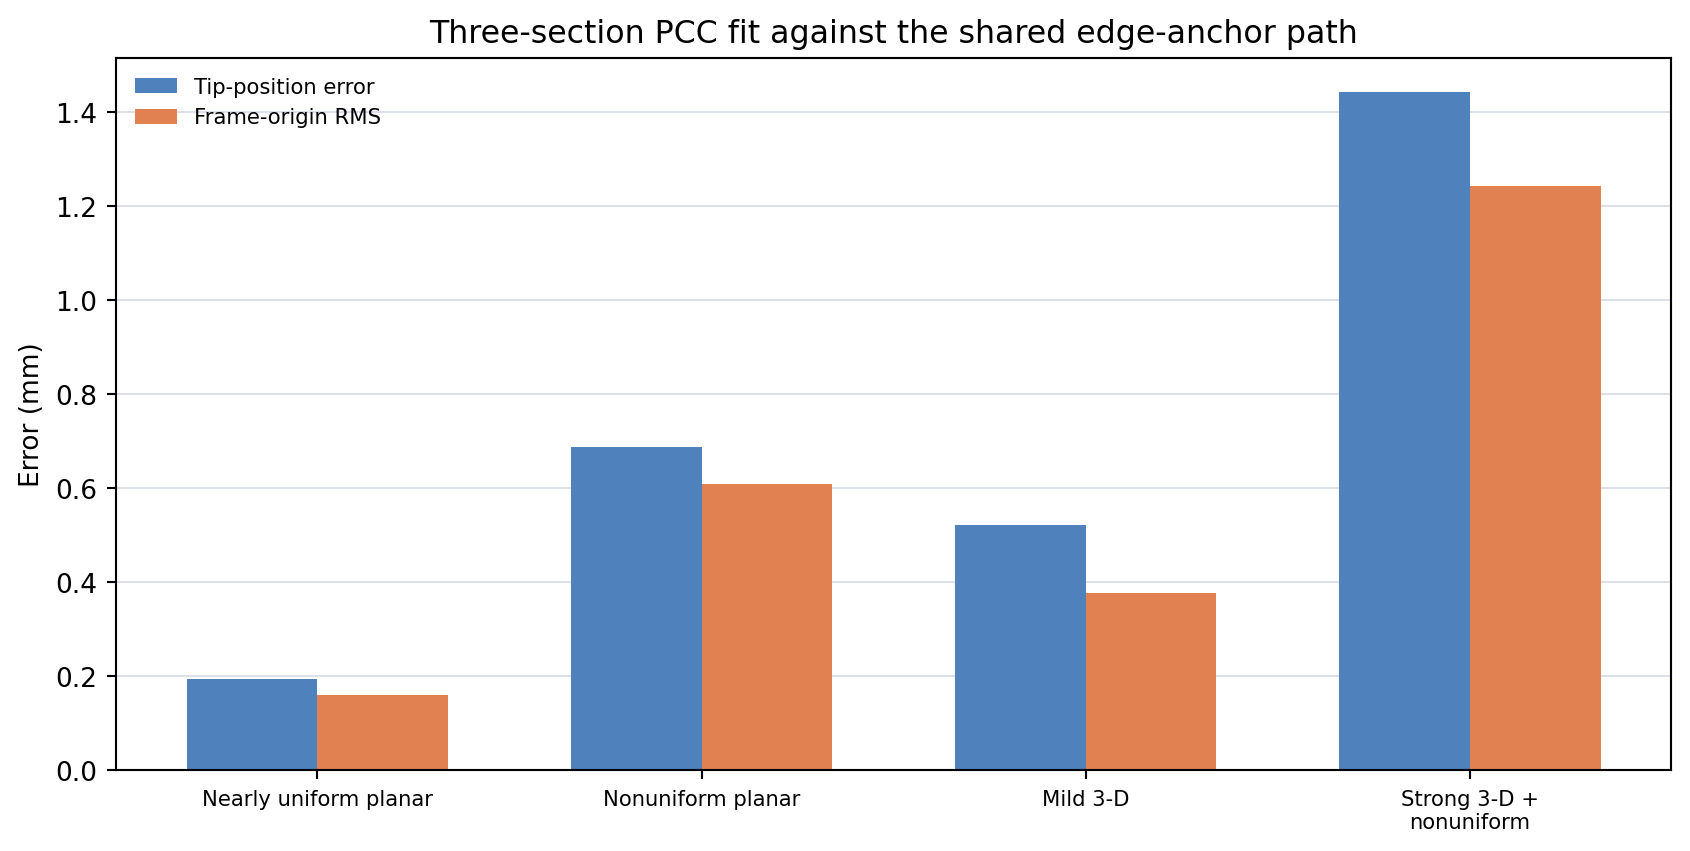
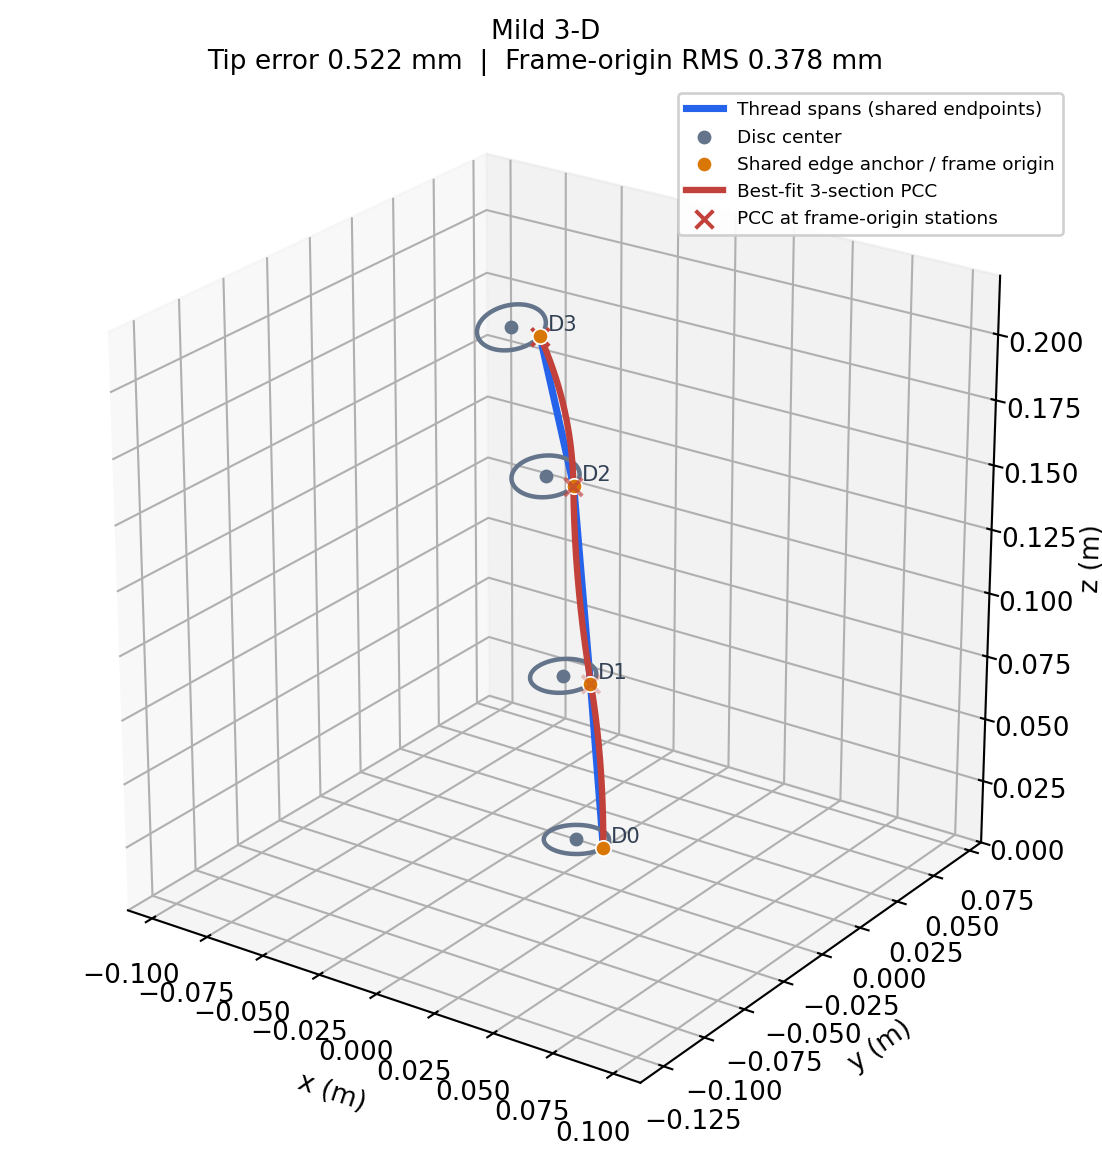
I work on mathematical models and geometry visualization for soft robotics. This update places each disc frame at the shared thread anchor and fits three piecewise constant-curvature sections to the non-root frame origins.
Scope
The saved run checks four synthetic geometries, including planar and three-dimensional cases. The drawing uses a 12 mm disc radius as a scale. It is an early geometry check, not experimental validation of a physical robot.